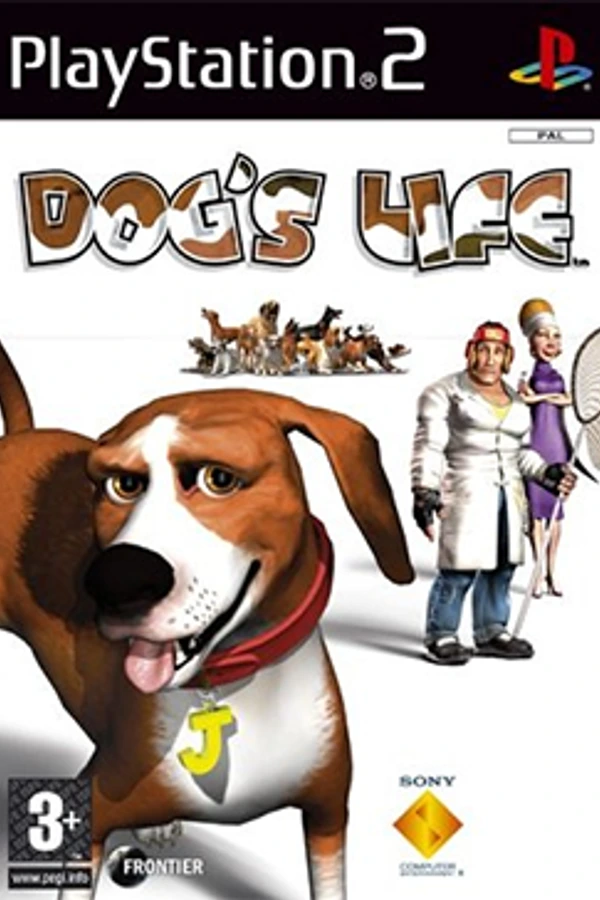
Dog's Life
TecnologíaPort Nativo C/C++ (Reimplementación de Motor)
Disponible paraWindows, Linux, macOS
Ver proyecto oficialSobre el proyecto
Dog's Life es un videojuego de acción-aventura desarrollado por Frontier Developments exclusivamente para PlayStation 2.
Información oficial del proyecto
Dogcomp: Dog's Life (2003) Decompilation Project
<a href="https://decomp.dev/IWILLCRAFT-M0d/dogcomp"><img src="https://decomp.dev/IWILLCRAFT-M0d/dogcomp.svg?mode=shield&measure=fuzzy_match_percent"/></a><a href="https://decomp.dev/IWILLCRAFT-M0d/dogcomp"> <a href="https://decomp.dev/IWILLCRAFT-M0d/dogcomp"><sup>Progress bar powered by decomp.dev</sup></a>
Dogcomp: A Dog's Life Decompilation Project. Currently working on the SCES_512.48 (PAL) release.
Setup
The setup can be built on Linux or Windows (through WSL). Follow the instructions below to set up the build environment.
1. Clone the repository
Clone the repo to your local machine:
git clone https://github.com/IWILLCRAFT-M0d/dogcomp && cd dogcomp
2. Extract your game's ELF file
Extract the file SCES_512.48 from your game copy and put it into the elf folder.
3. Setup Python environment
If you don't have Python 3.9 or higher, install it:
sudo apt-get install python3 python3-pip
Create a Python environment for the project:
python3 -m venv .venv
Activate the environment:
source .venv/bin/activate
Then install the required Python packages:
pip3 install -U -r requirements.txt
4. Setup build environment
Install the MIPS assembler:
sudo apt-get install binutils-mips-linux-gnu
Setup the compiler using the provided script:
./tools/setup_prodg_linux.sh
5. Configure and build the project
Run the configure script and the build with ninja:
python3 configure.py && ninja
The default behavior is to split the binary using Splat, build the object files (inserting the split assembly in place of non-matching functions), link the matching executable, and confirm that the checksum of the built executable matches the original.
You can change a little the behavior by passing any of the following arguments to configure.py:
--clean/-c- Delete any existing build files and configure the project.--clean-only/-C- Delete any existing build files without configuring the project.--skip-checksum/-s- Skip the checksum verification step.--objdiff/-diff- Builds target object files for comparison with Objdiff and generates an Objdiff configuration file.